Availability and configuration are agreed individually.
Wheels + legscompact mobility
22 kgbase-platform weight
5 kgbase-platform payload capacity
MEET THE PLATFORM
A closer look at D1 Ultra-W Patrol System.
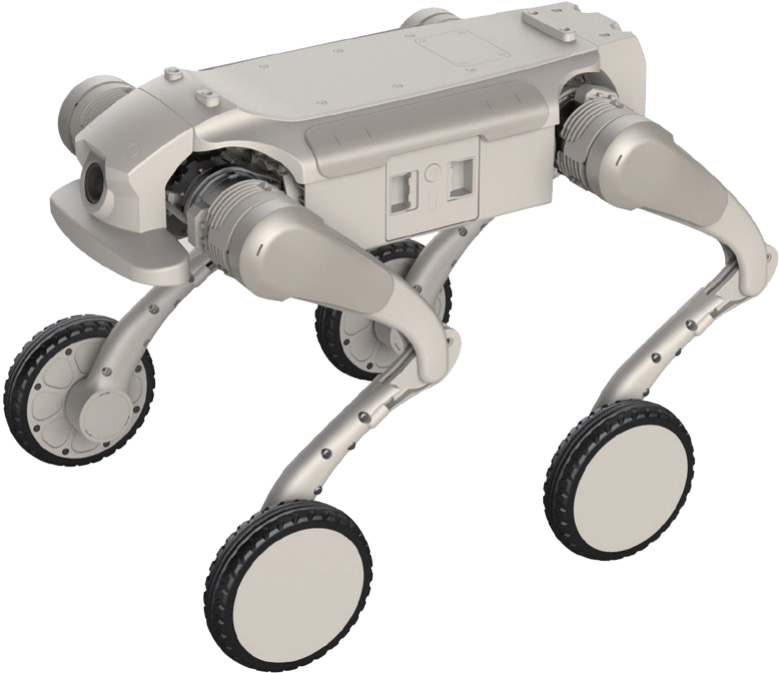
AGIBOT D1 Ultra-W base platform — distributor product image without a patrol payload.
Roll along corridors. Adapt to the terrain.
Ultra-W is the wheel-legged version of the compact D1 platform. The manufacturer identifies narrow corridors, routes between equipment, gravel and vegetation as potential operating environments. A site trial establishes whether the actual patrol route is accessible.
Equipment selected for the task.
Standard expansion interfaces support custom development and additional modules. Autonomous navigation requires sensing, computing capacity and software to be selected together.
Turn a route into an inspection task.
System design defines inspection points and expected results. A task is complete only when the robot has arrived and the required image or measurement is usable.
Validate the complete system during the pilot.
Test the equipped robot on the actual route. This allows battery endurance, network coverage and payload stability to be checked together in the same task.
Solution package: sensors, software, licences and services must be agreed item by item alongside the robot. Base-platform specifications below are reference values; payload equipment and site conditions affect complete-system performance.
Sensing and interaction
Sensors, software and licences
According to the itemised configuration
Camera and sensor package
Subject to project scope and itemised quotation
Control, software and connectors
Network coverage and remote monitoring
Subject to project scope and itemised quotation
Reports and integration interfaces
Subject to project scope and itemised quotation
Power and operating time
Docking and power supply
Subject to project scope and itemised quotation
Solution architecture and integration
Locomotion system
Wheel-legged design
Application objective
Site patrol and remote visual checks at inspection points; functionality implemented within the project
Navigation and mapping
Requires sensors and application software; not automatically included by virtue of the package name
Observation camera
Model, resolution, field of view, movement and night operation specified in the quotation
Image transmission
Camera, communication module, network connection and latency to be agreed
Complete system payload
Sensors, mounts, computing and communication equipment all count towards the platform payload
Complete system ingress protection
Must be verified for the payload and connections; the platform IP rating does not automatically apply to the complete package
Endurance with installed payload
Depends on route, payload and power consumption; may differ from the platform reference
Automatic charging
Dock, control software and site setup must be agreed separately; not confirmed as package contents
Deliverables
Itemised equipment list, agreed functions, operating procedure and pilot report according to project scope
The table below describes the associated robot platform, not the confirmed equipment of the D1 Ultra-W Patrol System. Package contents, total weight, power consumption and capabilities require separate agreement.
Can be implemented through development and selected sensors/software; not automatically included as standard
Based on the complete specification table in AGIBOT’s separate 2026 D1 Ultra-W publication. This is the 22 kg wheel-legged version, not the 16 kg D1 Ultra. Published values are laboratory data; the quotation specifies the supplied EU equipment.
Actual performance depends on the environment, load, software and configuration. Maximum values may reflect different test conditions and may not be achievable simultaneously.
DELIVERY & EQUIPMENT
Package contents and options.
Package contents subject to agreement
The selected D1 robot platform
Camera and sensor payload according to the itemised quotation
Computing, communication equipment and mounting components required for the system
Software modules and licences specified by name
Charging equipment, documentation and services within the agreed scope
To be agreed in the quotation
Which points need inspection, how often and with what result?
Which routes, stairs, slopes and weather conditions will be encountered?
What camera or measurement resolution is required?
Which network and supervisory system will receive the data?
How much operator involvement, on-site training and support is required?
The confirmed quotation itemises the equipment and licences included in the delivery. Illustrations may show optional accessories.
Applications.
Examples of possible uses. Required development and services are agreed for each project.
Long indoor routes
Wheel-leg movement for repeated corridor inspections.
Mixed-surface sites
A route combining paved areas and uneven ground, validated through a pilot.
Development projects
A compact wheel-legged platform for sensor integration and navigation research.
BEFORE CHOOSING YOUR CONFIGURATION
Frequently asked questions.
How do Patrol and Inspection packages differ?
Patrol focuses on covering an area and observing conditions; Inspection focuses on checking specific equipment or measurements. Hardware and software are selected accordingly.
Is every pictured device included?
Images illustrate possible configurations. The confirmed item list determines cameras, sensors, computers, communication hardware and licences.
Can it independently navigate an unfamiliar site?
That is not a default capability. Autonomous operation requires suitable sensing, mapping, software and on-site validation, with operating boundaries and supervision defined for the project.
Are base-platform figures unchanged after integration?
Not necessarily. Payload weight, centre of gravity and power consumption affect mobility and runtime. Base-platform specifications remain a separate reference.
Manufacturer: AGIBOT. Platform data comes from the referenced manufacturer documentation; distributor images illustrate configurations. For custom solution packages, the reference describes the base platform.
NT SYS · AGIBOT ROBOTICS
Let’s discuss your application.
We help select the right model, equipment and services.