Availability and configuration are agreed individually.
Patrolsite monitoring
25 kgbase-platform payload capacity
2 batteriesreplaceable power supply
MEET THE PLATFORM
A closer look at D1 Max Patrol System.
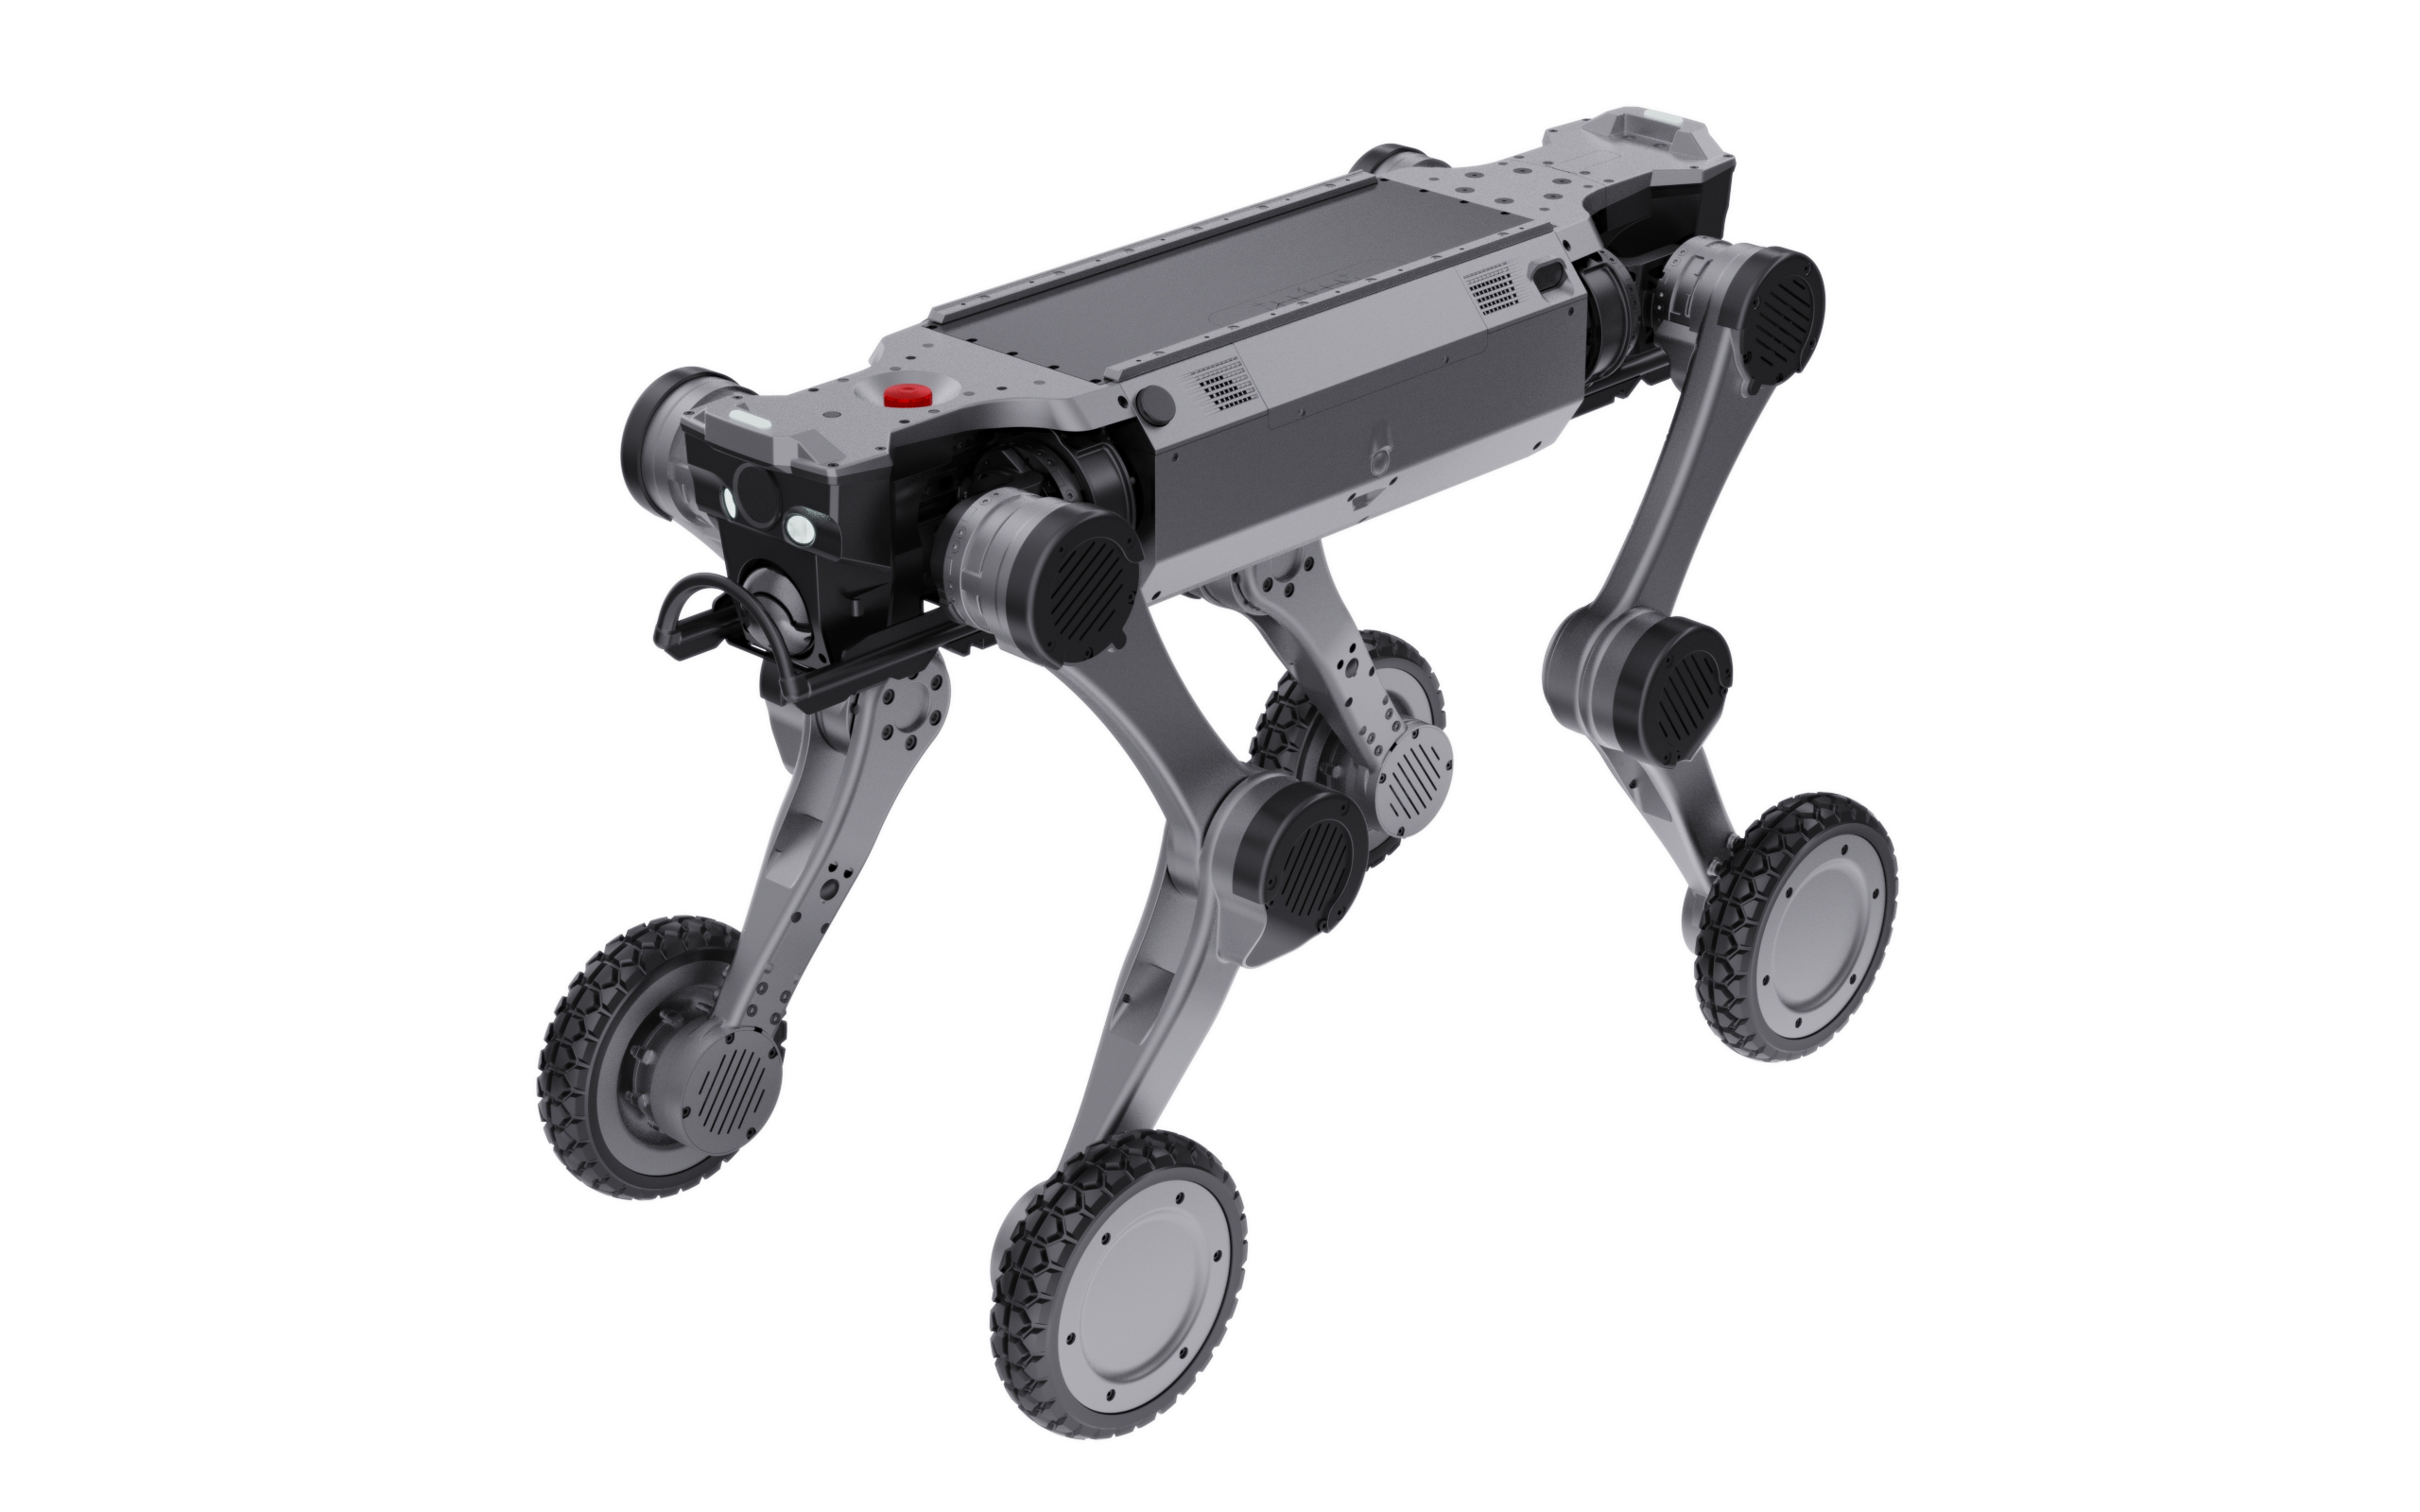
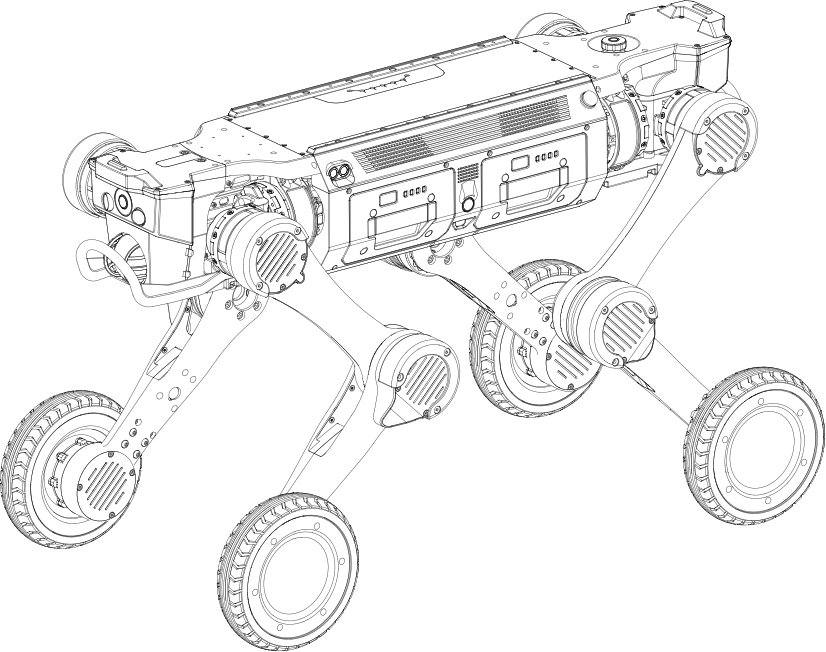
AGIBOT base-platform illustration; the final payload configuration is agreed separately.
A mobile observation point across the site.
D1 Max combines rolling on paved routes with legged movement over uneven terrain. The Patrol configuration focuses on site coverage and remote situational assessment, while the Inspection package addresses measurement tasks on specific equipment.
Equipment selected for the task.
Observation cameras and navigation sensors serve different purposes. Cameras support remote monitoring; LiDAR and positioning systems help the robot navigate. Camera field of view, movement and data connectivity are matched to the patrol route.
Turn a route into an inspection task.
System design defines inspection points and expected results. A task is complete only when the robot has arrived and the required image or measurement is usable.
Validate the complete system during the pilot.
Test the equipped robot on the actual route. This allows battery endurance, network coverage and payload stability to be checked together in the same task.
Solution package: sensors, software, licences and services must be agreed item by item alongside the robot. Base-platform specifications below are reference values; payload equipment and site conditions affect complete-system performance.
Sensing and interaction
Sensors, software and licences
According to the itemised configuration
Camera and sensor package
Subject to project scope and itemised quotation
Control, software and connectors
Network coverage and remote monitoring
Subject to project scope and itemised quotation
Reports and integration interfaces
Subject to project scope and itemised quotation
Power and operating time
Docking and power supply
Subject to project scope and itemised quotation
Solution architecture and integration
Locomotion system
Wheel-legged design
Application objective
Site patrol and remote visual checks at inspection points; functionality implemented within the project
Navigation and mapping
Requires sensors and application software; not automatically included by virtue of the package name
Observation camera
Model, resolution, field of view, movement and night operation specified in the quotation
Image transmission
Camera, communication module, network connection and latency to be agreed
Complete system payload
Sensors, mounts, computing and communication equipment all count towards the platform payload
Complete system ingress protection
Must be verified for the payload and connections; the platform IP rating does not automatically apply to the complete package
Endurance with installed payload
Depends on route, payload and power consumption; may differ from the platform reference
Automatic charging
Dock, control software and site setup must be agreed separately; not confirmed as package contents
Deliverables
Itemised equipment list, agreed functions, operating procedure and pilot report according to project scope
AGIBOT D1 Max — complete base-platform specifications
The table below describes the associated robot platform, not the confirmed equipment of the D1 Max Patrol System. Package contents, total weight, power consumption and capabilities require separate agreement.
Aluminium alloy and high-strength engineering plastic
Standing dimensions (L × W × H)
930 × 480 × 585 mm
Lying dimensions (L × W × H)
930 × 630 × 200 mm
Weight including battery
41 kg
Degrees of freedom
12 + 4
Operating temperature
−20…55 °C
Ingress protection
IP67
Battery and range
Battery
54 V; 2 × 504.9 Wh
Battery replacement
Dual batteries with hot-swap support
Charging time
< 1.5 hours
Unloaded endurance
5 ± 0.5 hours in the specification table
Endurance at full payload
3.5 ± 0.5 hours in the specification table
Unloaded range
29 ± 1 km
Range at full payload
18 ± 1 km
Motion and payload
Maximum speed
6 m/s, manufacturer laboratory reference
Rated payload
25 kg
Continuous stair-climbing height
25 cm
Maximum slope
45°
Maximum obstacle clearance
80 cm
Obstacle clearance under load
50 cm
Turning capability
Turning on the spot; adjustable forward and backward crawling height
Crawling height
34 ± 0.5 cm
Basic motion functions
Stepping, sliding, crawling; forward, backward and sideways movement, rotation on the spot and steering; adjustable knee configuration
Wheel and leg modes
Intelligent mode switching
Joint specifications
Maximum joint torque
150 Nm
Body joint range
−30°…40°
Thigh joint range
−160°…160°
Shin joint range
−160°…160°
Sensors
Number of LiDAR sensors
2 units: front and rear
LiDAR channel count
96 channels per sensor
LiDAR coverage
360° × 90°; 120 m coverage diameter as stated by the manufacturer
FPV cameras
2 units: front and rear; industrial version, 8 MP
Camera field of view
122° diagonal, 111° horizontal, 70° vertical
Auxiliary lighting
4 lights on either side of the FPV cameras
IMU
1 unit, manufacturer automotive-grade version
RTK module
1 × GNSS RTK
Ultrasonic sensors
1 on each side; obstacle detection within 5 m
Computing and interfaces
Computing performance
100–157 TOPS; NVIDIA Orin NX 16 GB
Real-time video transmission
Supported
Secondary development
SDK; 3D CAD and URDF robot models for simulation
Wireless connectivity
Wi-Fi 5.0, Bluetooth 5.0
Power outputs
5 V, 12 V, 24 V, 48 V; total up to 480 W
Gigabit Ethernet
2 ports
USB
2 × USB 3.0
Serial interfaces
1 × RS232, 1 × RS485
Additional interfaces
2 × SBUS, 1 × PPS
Accessories
Adapter
Standard equipment
Charging base
Standard equipment
Remote controller
With built-in display
Autonomous charging station
Optional
Data from the complete D1 Max manufacturer specification table. The presentation page also states ≥5 / ≥3.5 hours and ≥29 / ≥18 km; the detailed table gives tolerances, and its values are used here. Laboratory measurements do not guarantee performance at every site.
Actual performance depends on the environment, load, software and configuration. Maximum values may reflect different test conditions and may not be achievable simultaneously.
DELIVERY & EQUIPMENT
Package contents and options.
Package contents subject to agreement
The selected D1 robot platform
Camera and sensor payload according to the itemised quotation
Computing, communication equipment and mounting components required for the system
Software modules and licences specified by name
Charging equipment, documentation and services within the agreed scope
To be agreed in the quotation
Which points need inspection, how often and with what result?
Which routes, stairs, slopes and weather conditions will be encountered?
What camera or measurement resolution is required?
Which network and supervisory system will receive the data?
How much operator involvement, on-site training and support is required?
The confirmed quotation itemises the equipment and licences included in the delivery. Illustrations may show optional accessories.
Applications.
Examples of possible uses. Required development and services are agreed for each project.
Industrial sites
Visit inspection points regularly across larger industrial areas.
Outdoor perimeter monitoring
Observe gates and fence sections after assessing weather and connectivity conditions.
Remote assessment
An operator can send the robot to an event location and assess the situation through its camera.
BEFORE CHOOSING YOUR CONFIGURATION
Frequently asked questions.
How do Patrol and Inspection packages differ?
Patrol focuses on covering an area and observing conditions; Inspection focuses on checking specific equipment or measurements. Hardware and software are selected accordingly.
Is every pictured device included?
Images illustrate possible configurations. The confirmed item list determines cameras, sensors, computers, communication hardware and licences.
Can it independently navigate an unfamiliar site?
That is not a default capability. Autonomous operation requires suitable sensing, mapping, software and on-site validation, with operating boundaries and supervision defined for the project.
Are base-platform figures unchanged after integration?
Not necessarily. Payload weight, centre of gravity and power consumption affect mobility and runtime. Base-platform specifications remain a separate reference.
Manufacturer: AGIBOT. Platform data comes from the referenced manufacturer documentation; distributor images illustrate configurations. For custom solution packages, the reference describes the base platform.
NT SYS · AGIBOT ROBOTICS
Let’s discuss your application.
We help select the right model, equipment and services.